Advanced mobility under desert conditions
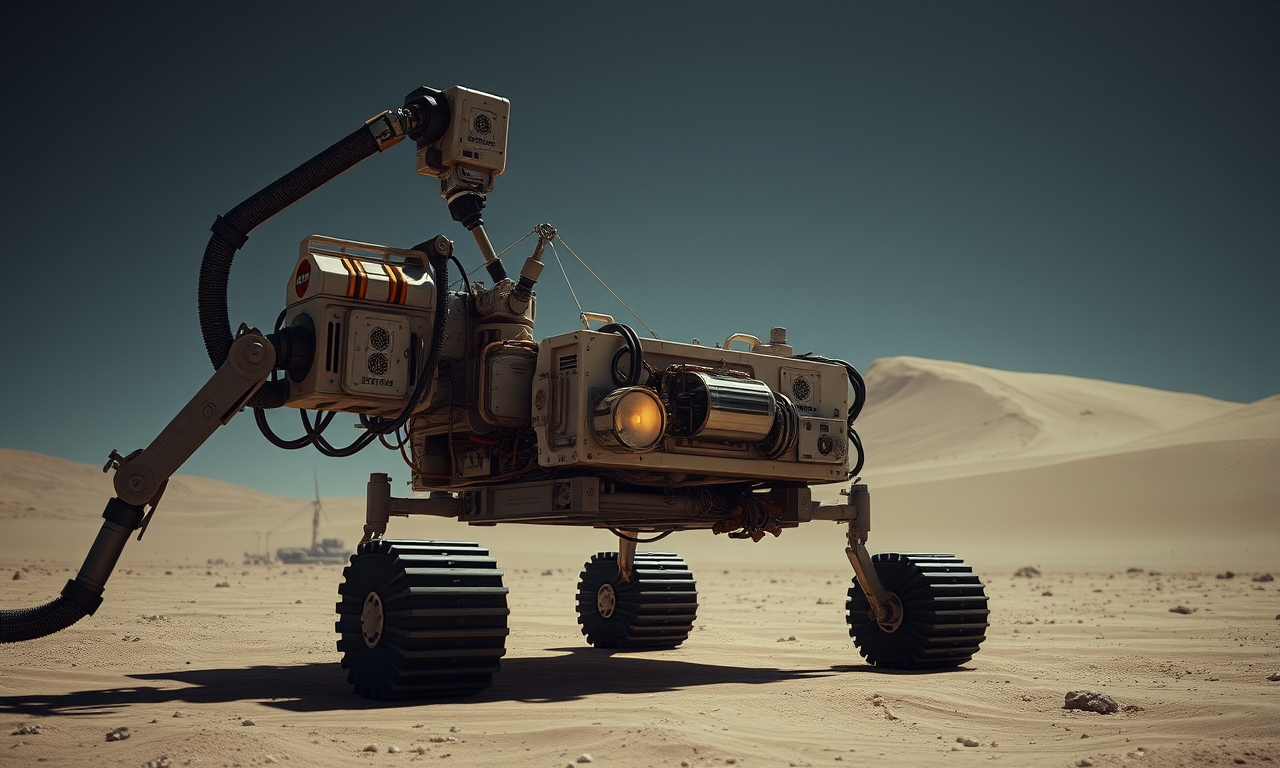
In March 2026 the Jet Propulsion Laboratory (JPL) of NASA carried out a field trial of a new rover prototype in the Colorado Desert close to Plaster City, California. The four‑wheel vehicle, named ERNEST (Exploration Rover for Navigating Extreme Sloped Terrain), was tasked with evaluating novel drive‑train and suspension concepts on real desert terrain.
Autonomy as the primary test objective
The exercise focused on validating autonomy software that enables the rover to independently assess and navigate complex, uneven ground. By fusing data from lidar, cameras and inertial sensors, the system identifies obstacles, evaluates slopes and computes safe paths without continuous commands from a ground station.
Findings and next steps
During the multi‑day deployment ERNEST successfully negotiated steep dunes, loose sand and rocky outcrops. The collected data are now being analyzed to refine the navigation algorithms and to assess the durability of the drivetrain. The team intends to incorporate the proven technologies into future lunar or Martian missions, where similar terrain challenges are expected.
Implications for future exploration
Autonomous operation in extreme terrain is regarded as a critical capability for exploring distant celestial bodies. The successful desert trial marks a significant milestone for NASA’s development of rover systems that could support upcoming crewed or robotic missions beyond Earth.